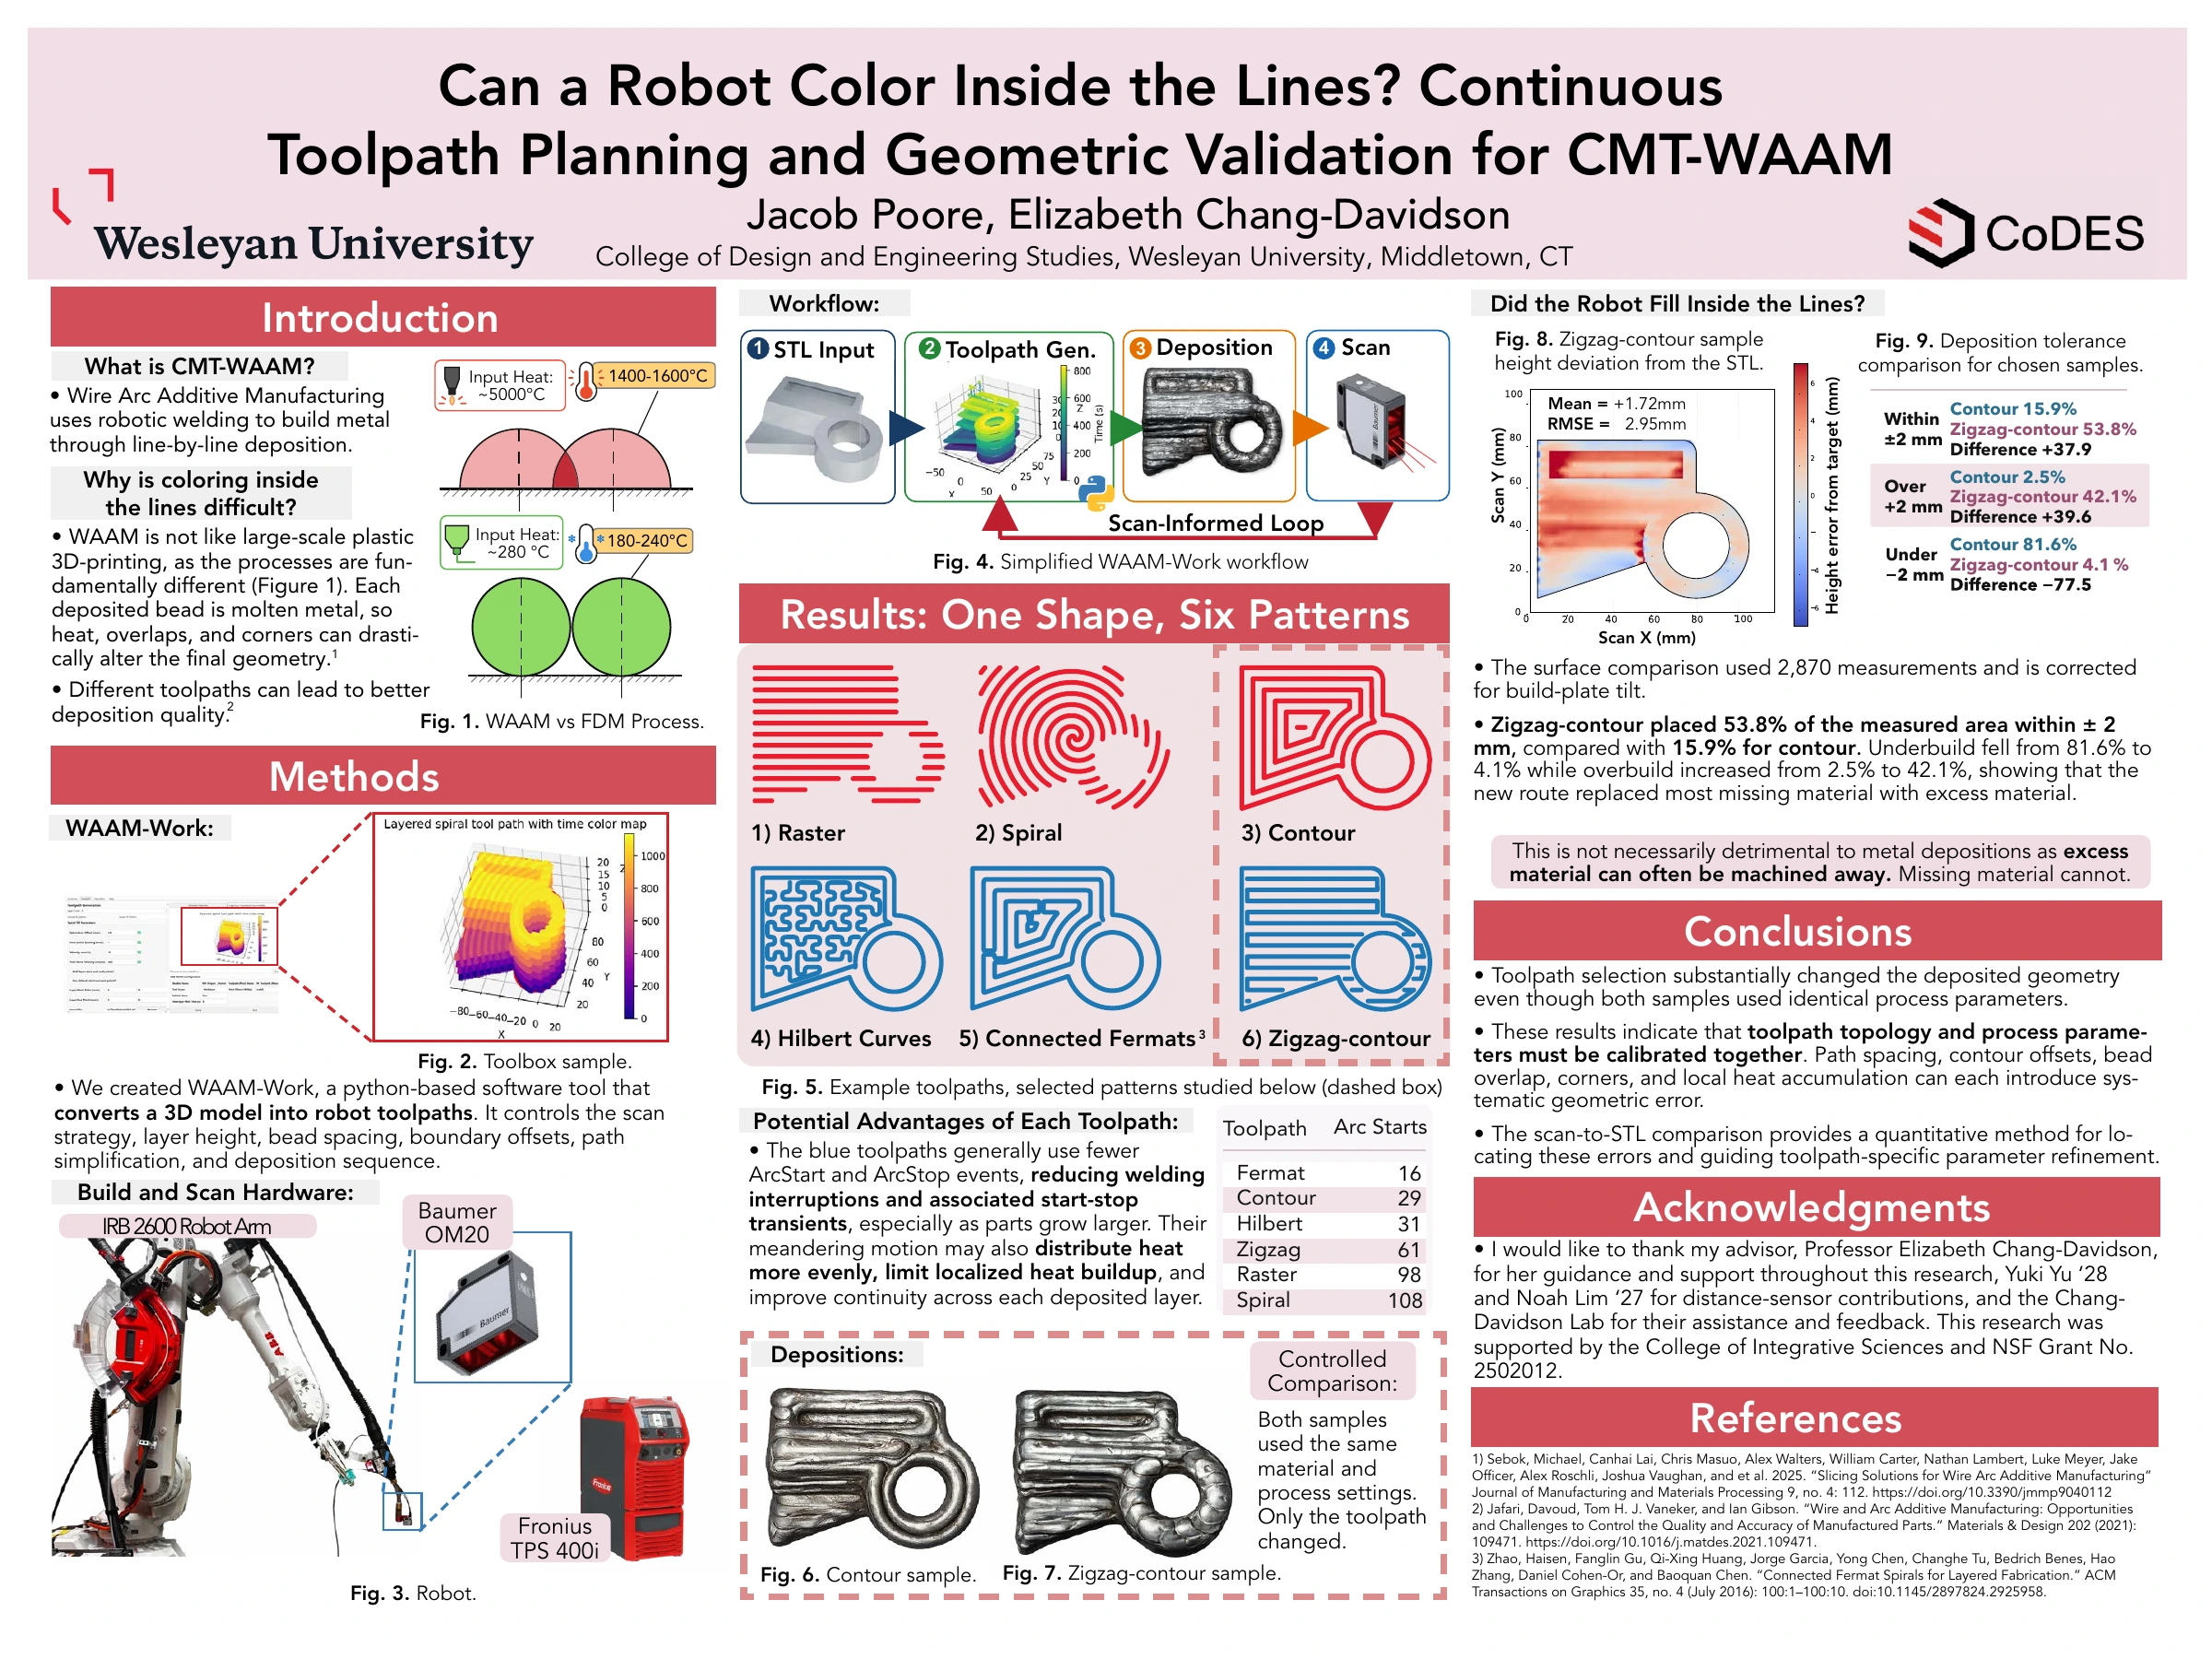
Can a Robot Color Inside the Lines? Continuous Toolpath Planning and Geometric Validation for CMT-WAAM
Jacob Poore and Elizabeth Chang-Davidson
Available · Supplied research poster
Chang-Davidson Laboratory · Wesleyan University
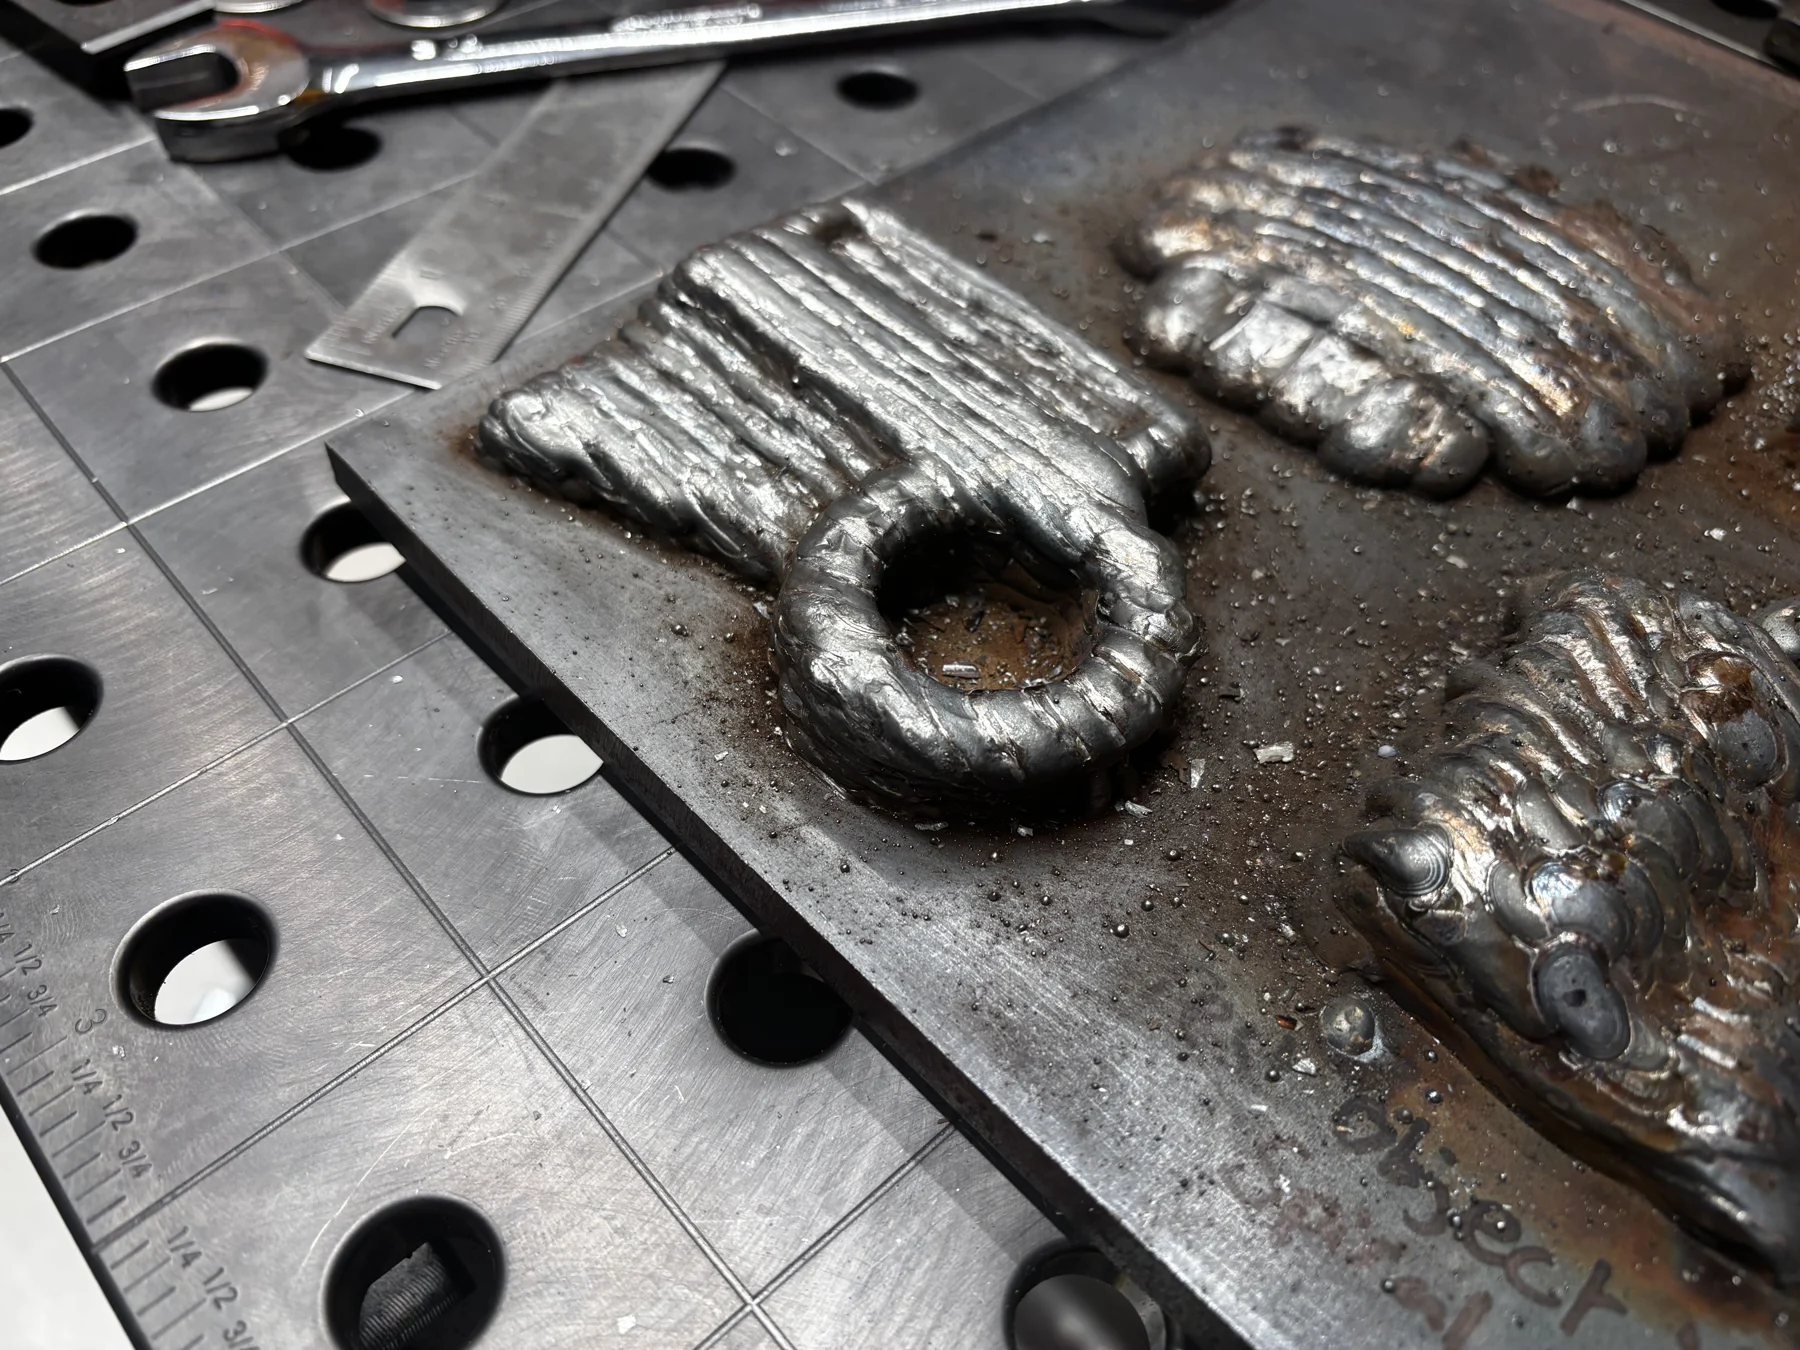
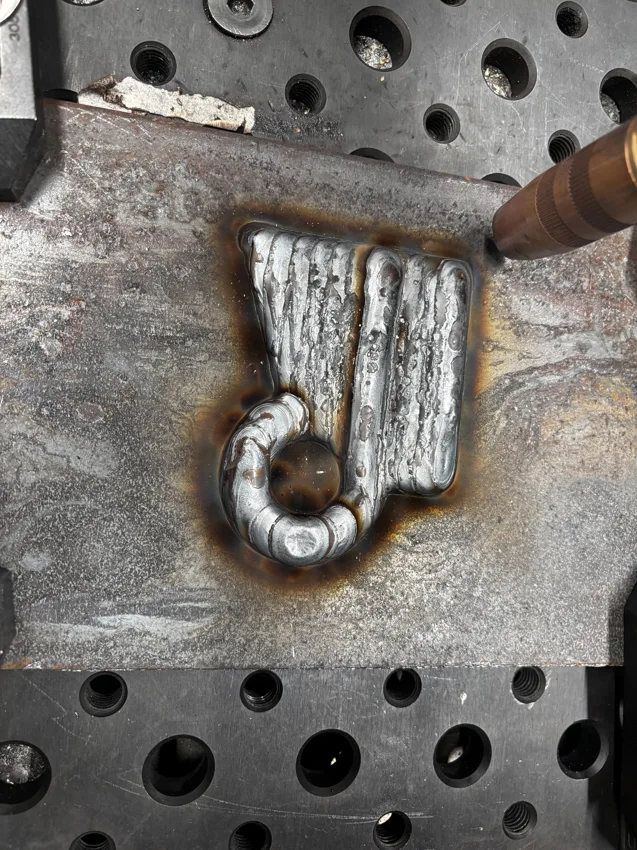
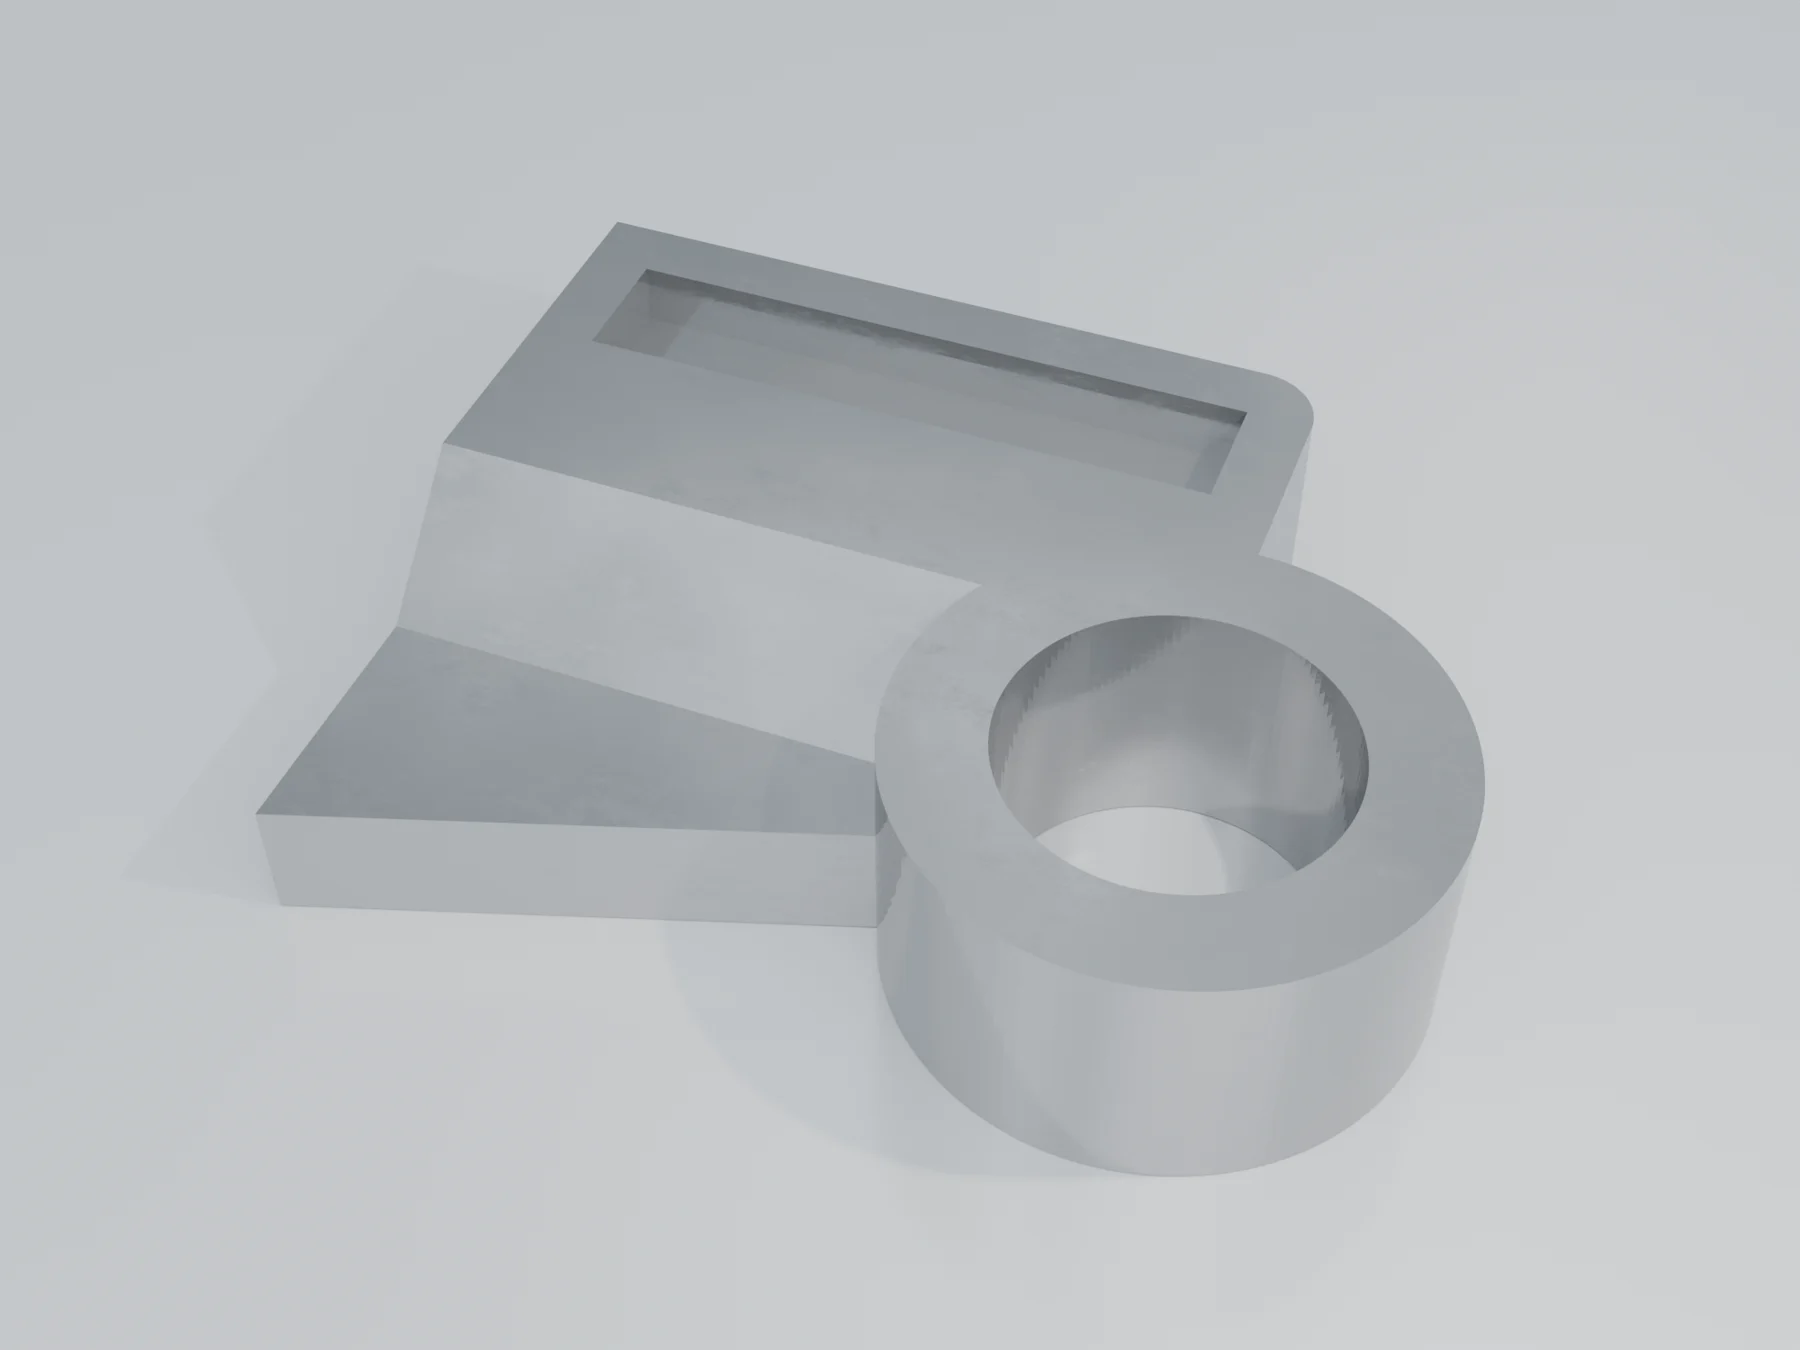
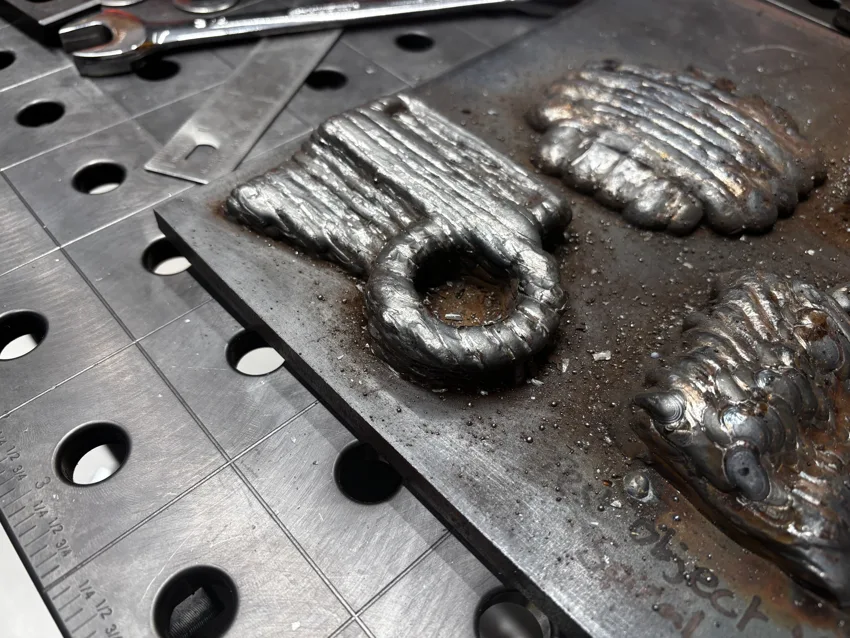
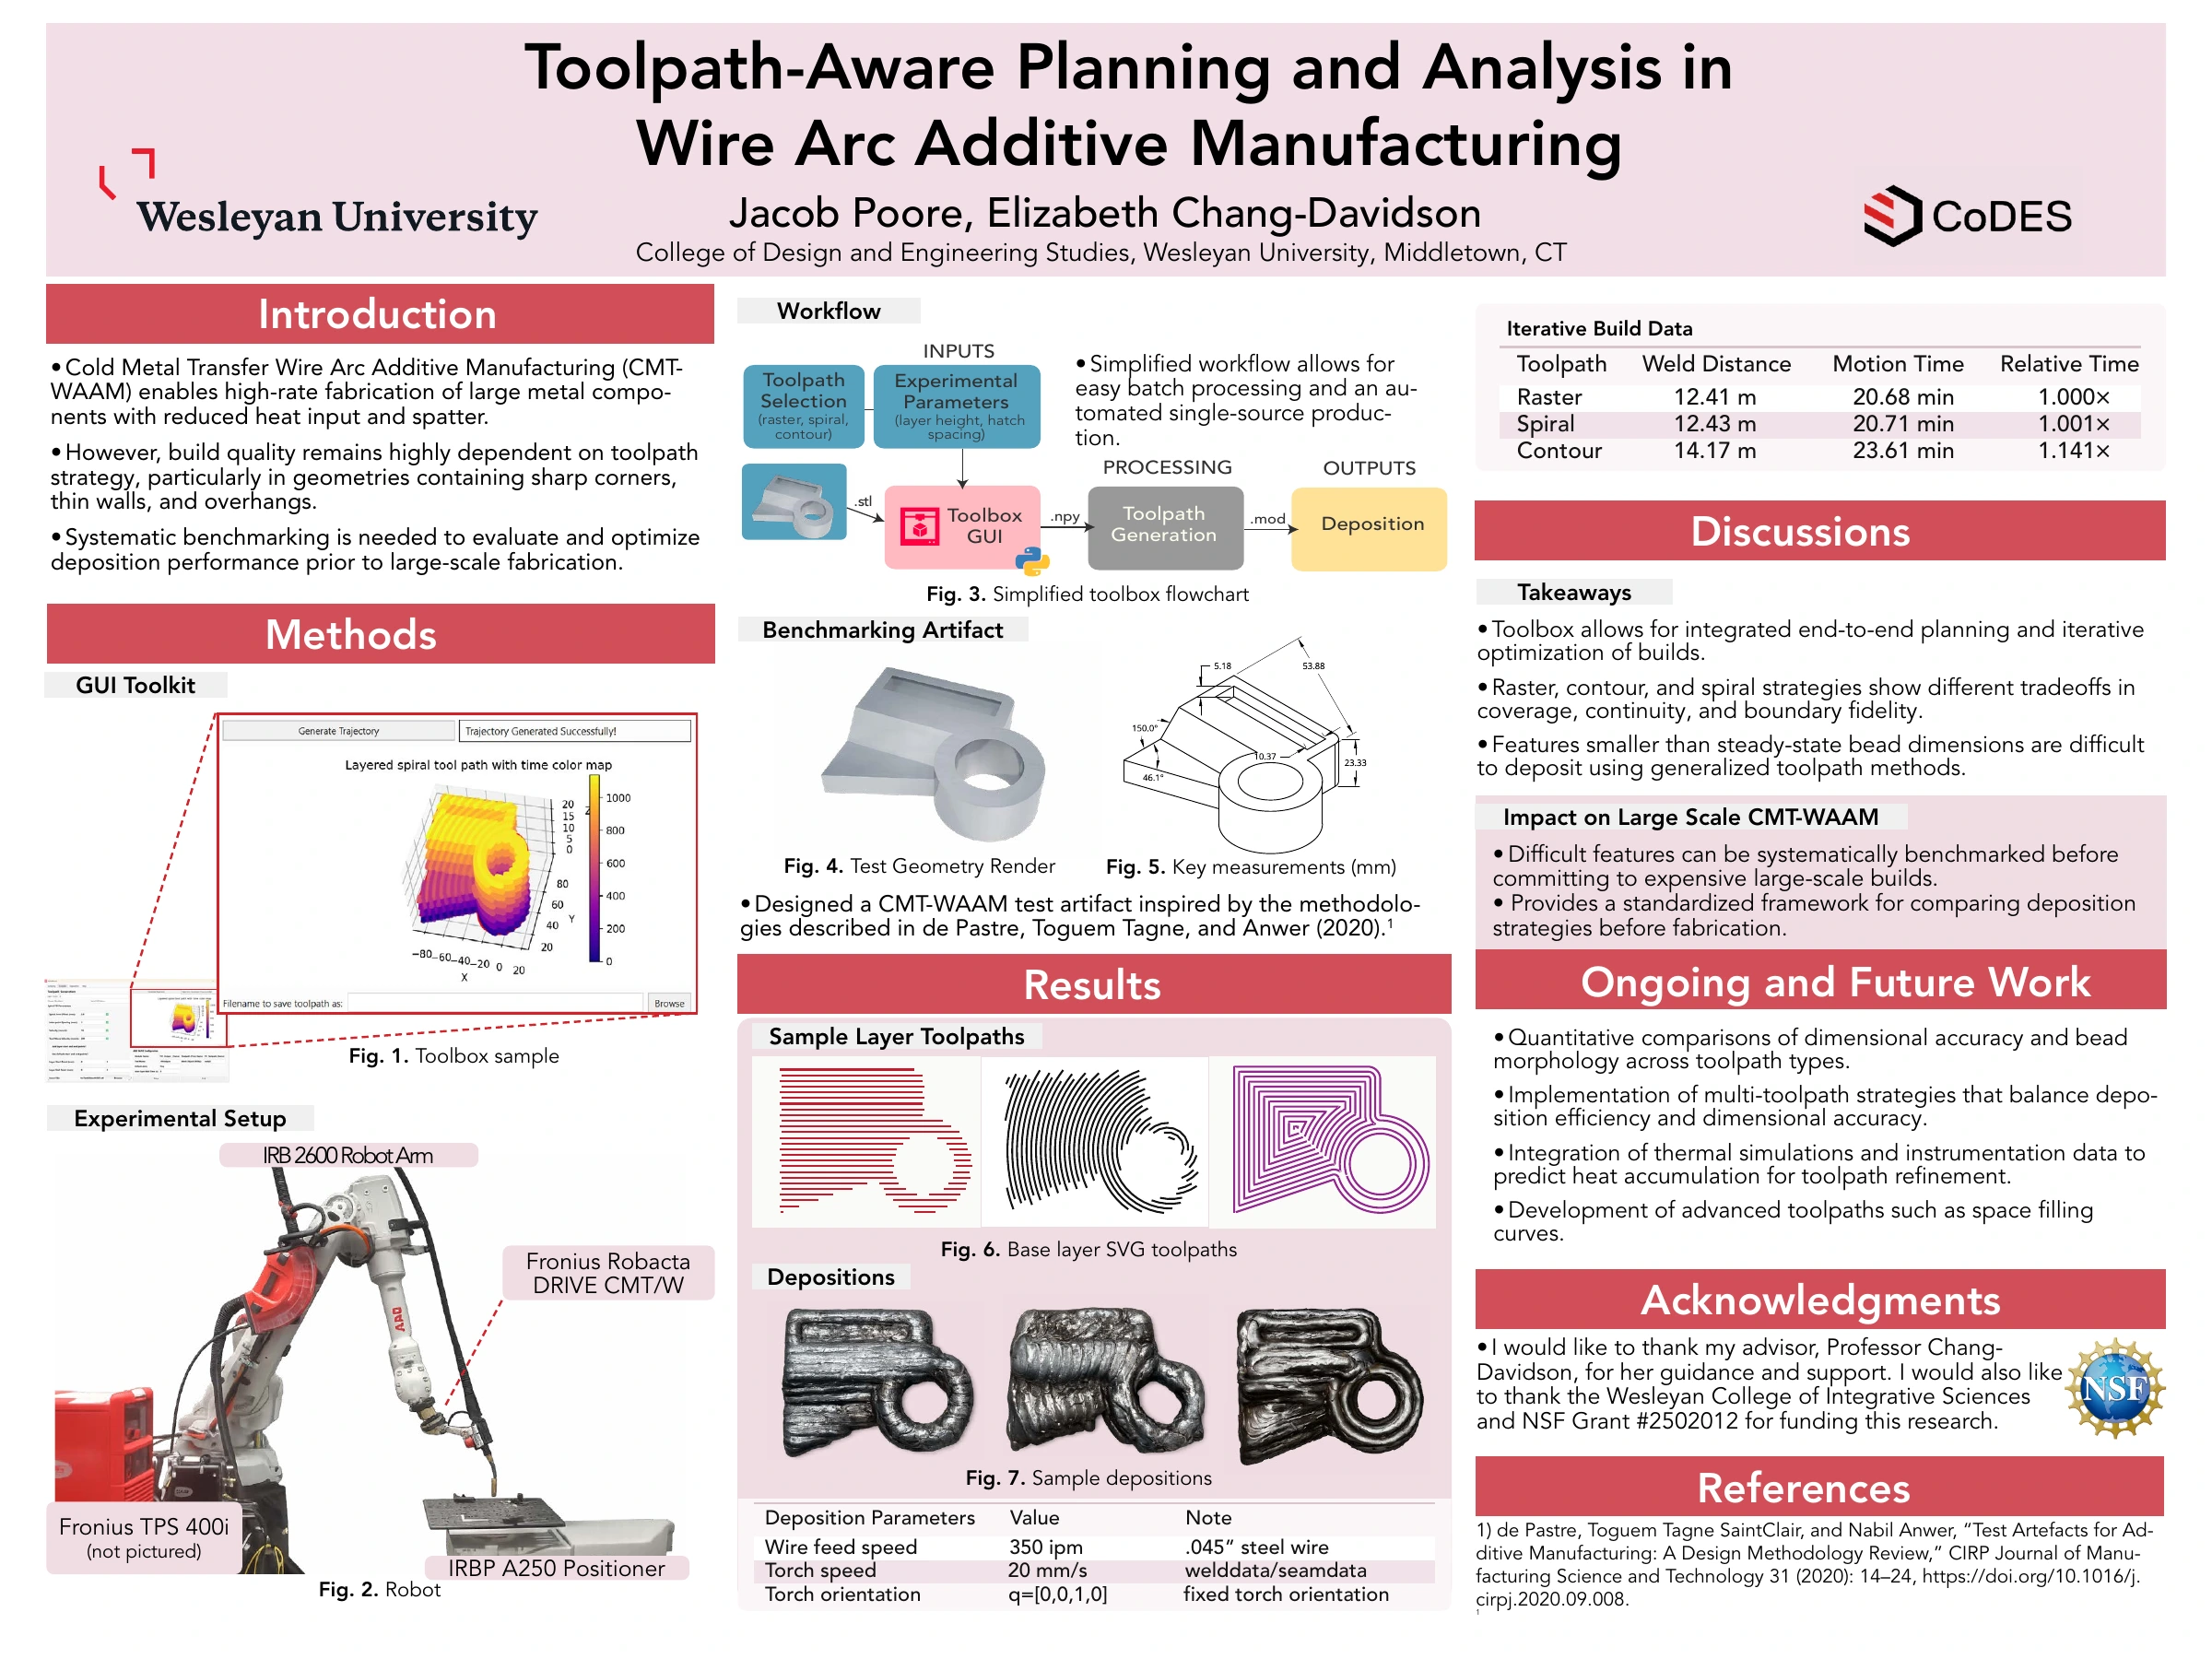
I work on robotic metal additive manufacturing: how we plan a deposition path, translate it into robot motion, and understand the shape that results.
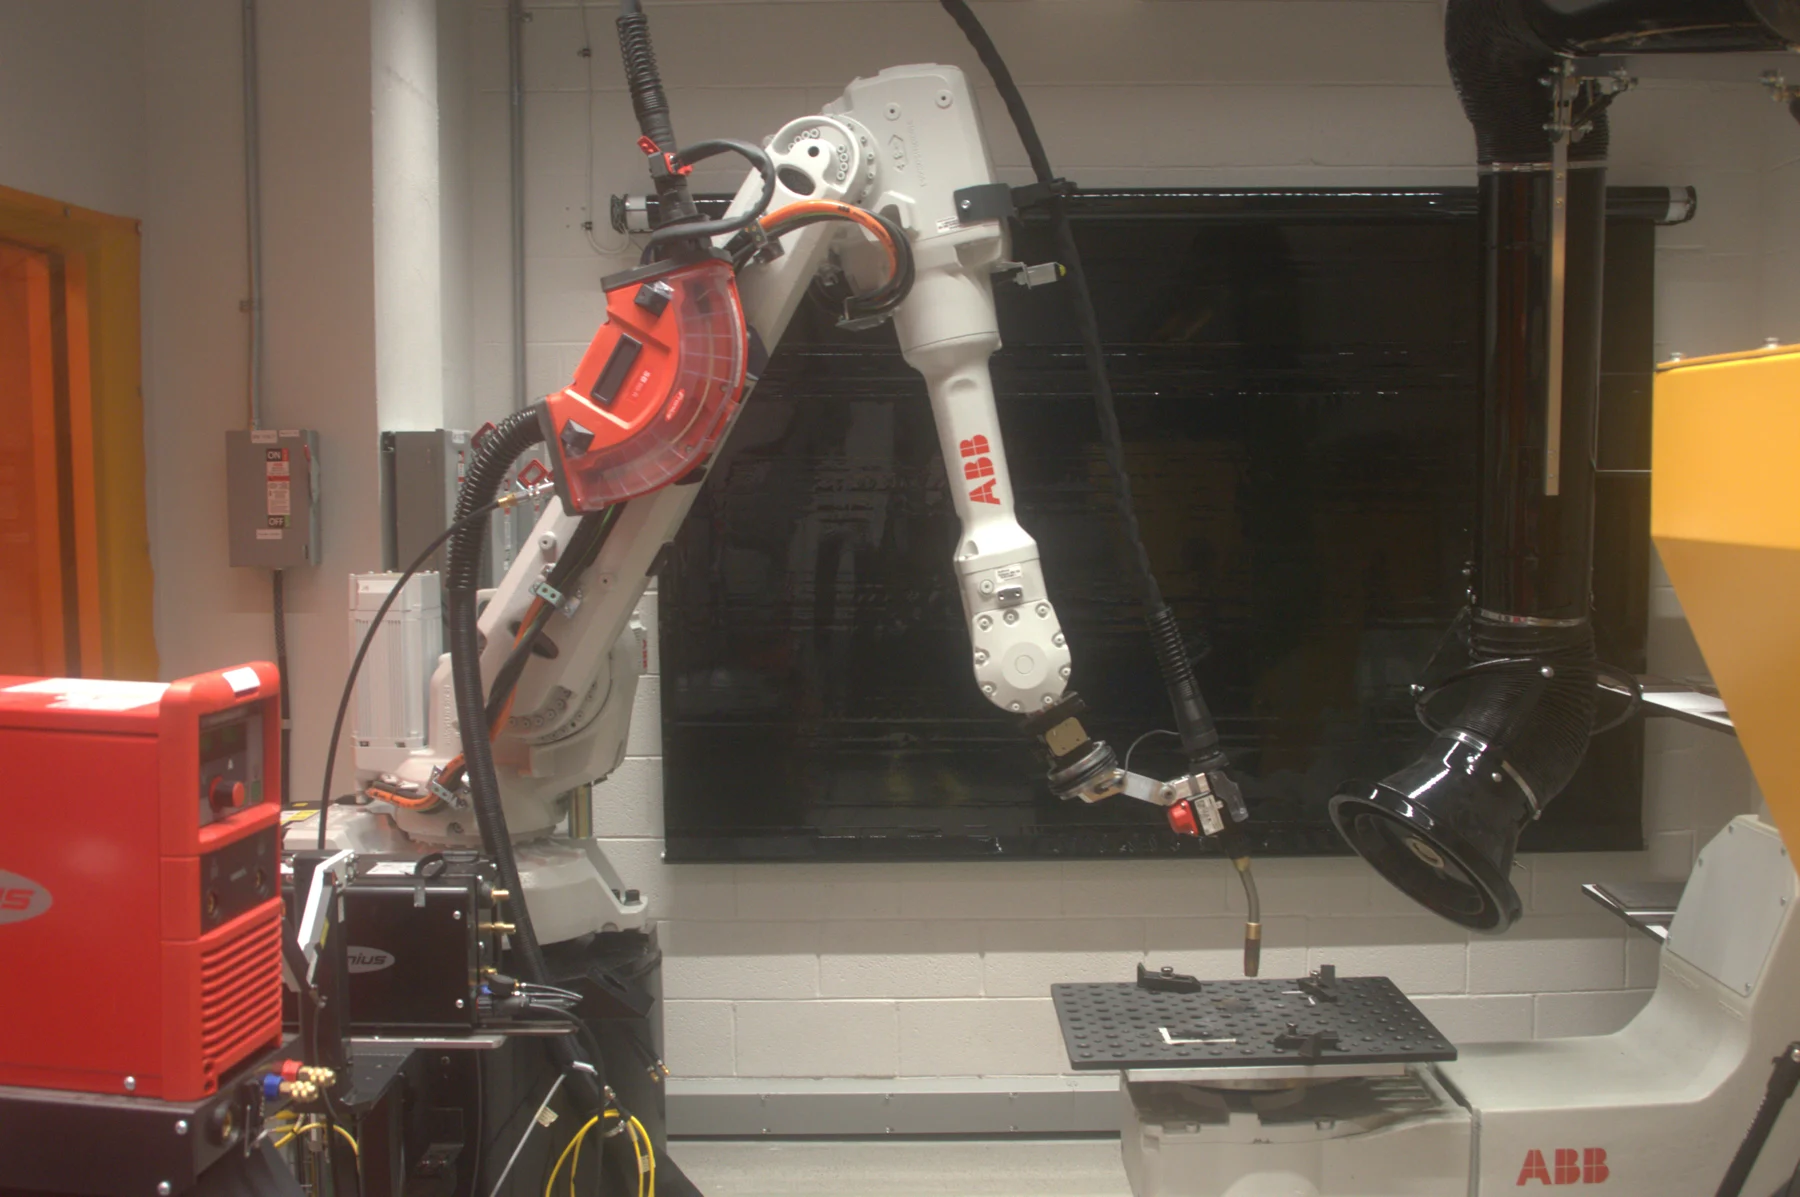
Our laboratory uses Cold Metal Transfer (CMT) welding with an ABB industrial robot and Fronius welding equipment. My work brings together computational toolpath generation, deposition planning, ABB RAPID programming, and RobotStudio.
Further project details will be shared when they are ready for public release.
Jacob Poore and Elizabeth Chang-Davidson
Available · Supplied research poster
Jacob Poore and Elizabeth Chang-Davidson
Available · Supplied research poster